

3D Model Full Coverage
Based on parameters and operational characteristics of various elements in actual scenarios, builds digital twin models for the full range of Guozi robot vehicle models, shelf models, machine equipment, etc.
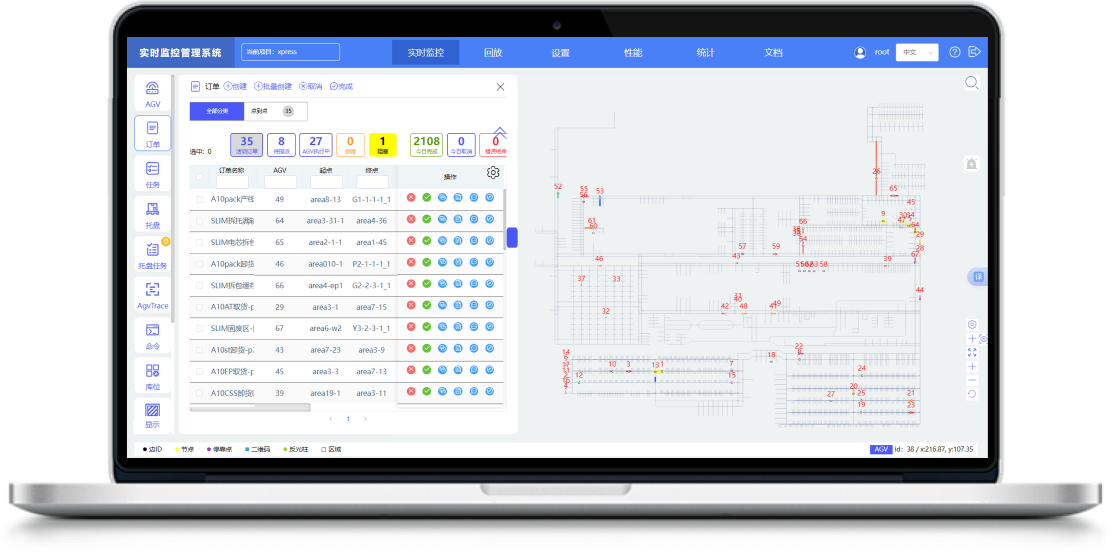
Multi-source Information Display
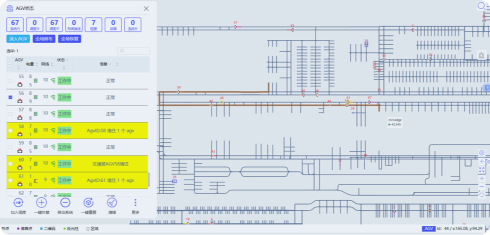
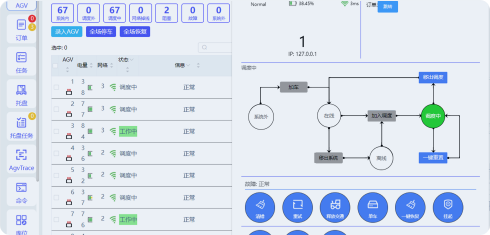
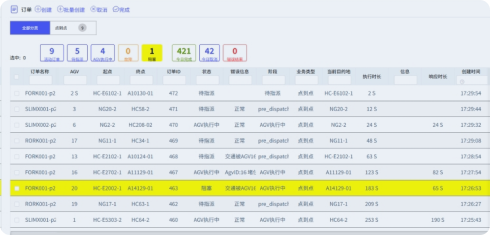
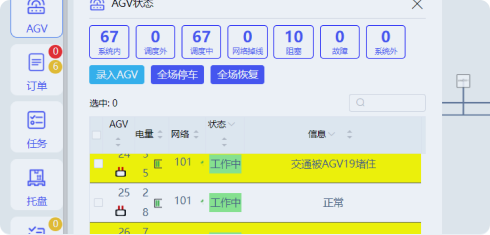
Supports display of all AGV real-time status, AGV real-time tasks, AGV real-time trajectories and alarm information, as well as order information and device interaction information for each process.
Scene Layout Configurable
Supports layout configuration for various physical models to quickly adapt to scene changes.
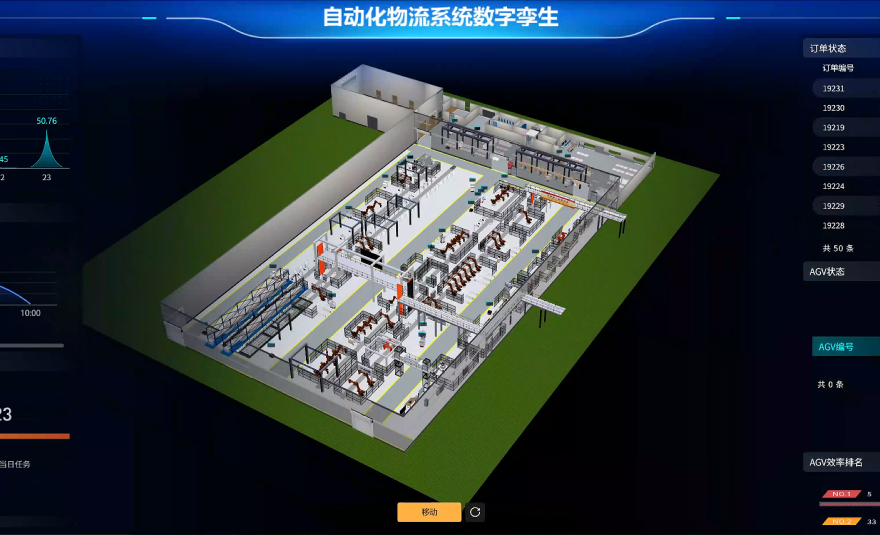
Digital twin 3D display supports immersive viewing from various angles. Remotely, you can easily understand the full picture and local key information of the scene, providing decision support for improving AGV operation efficiency.
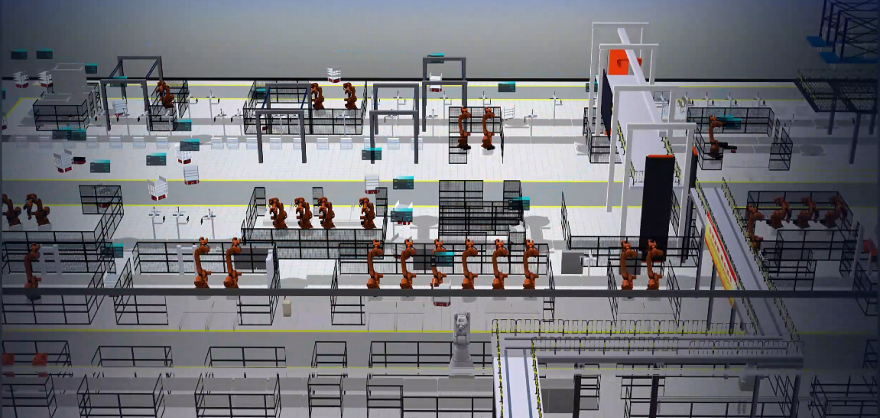
Uses hardware-driven simulation technology to fully simulate AGV chassis movement, navigation line tracking, loading/unloading action details, and PLC device interaction processes. It can simulate various anomalies such as network disconnection, interaction delays, and AGV faults, with simulation results highly consistent with actual system operation.
Simplifies AGV chassis movement and navigation line tracking to movement along task routes at set speeds, using time delays to replace AGV loading/unloading action time. This saves simulation server storage and computing resources, allowing 100-AGV project simulation on ordinary laptops, with support for up to 5x accelerated simulation. Easily enables simulation of 500+ AGV scale projects.
Phone:
400-826-2700
Head Office: Building B, No. 398 Shiqiao Road, Gongshu District, Hangzhou, Zhejiang, China
Manufacturing Base: No. 2799 Dayuan Road, Qingshanhu Subdistrict, Lin'an District, Hangzhou, Zhejiang, China
Email: agv@hcforklift.com | sales@gzrobot.com
 LinkedIn
HCGZ Intelligence Co., Ltd. © All Rights Reserved 浙ICP备05002928号 浙ICP备12023304号 浙公网安备 33018302001234号
Tech Support: Yike Data